Robotics & perception
Autonomous robot car
A Jetson Nano robot car combining object detection, collision avoidance, and target localization.
Graduation project · University of Khartoum
- Undergraduate study period
- 2014–2020Within my undergraduate study period
- Organization
- University of Khartoum
- Project type
- Graduation project
- My role
- Autonomous system development
- Location
- Khartoum, Sudan
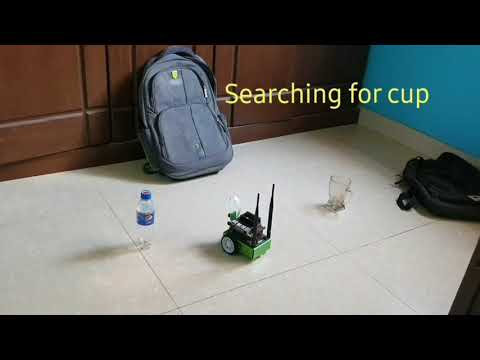 ▶ Play demonstrationClose video ↑
The problem
Scope & contribution
Build a mobile robot that can navigate its environment, find target objects, and report their locations.
- Developed a real-time autonomous robot car powered by NVIDIA Jetson Nano.
- Used Tiny-YOLOv3 for object detection and a custom binary-classification CNN for collision avoidance.
- Integrated navigation, target-object search, and transmission of detected object locations.